










Current tag:robot arm
 How Should Manufacturers Upgrade Harmonic Joint Modules for Robotic Arms and Embodied AI in 2026?For engineers planning a robotic system upgrade, the right joint module depends on more than a single specification. EtherCAT synchronization, output-side position feedback, real-time torque measurement, continuous torque capability, and integrated safety functions must work together to meet the demands of the application. By evaluating these factors as a complete electromechanical system, manufacturers can make more informed decisions about joint module selection, integration, and long-term performance.
- STO vs. Holding Brake in Robot Joint Modules: What Is the Difference for Robot Safe Control?STO (Safe Torque Off) and holding brakes play different roles in robot joint safety. While STO prevents a motor from generating driving torque, a holding brake mechanically resists joint movement and helps retain loads when the motor is disabled. Understanding the difference is essential when selecting a robot joint module for humanoid robots, collaborative robots, and industrial automation. In this article, Theodore Li, Technical Director at HONPINE, explains how these functions work, their limitations, and when both should be considered in a harmonic integrated joint actuator such as the HONPINE HAG series.
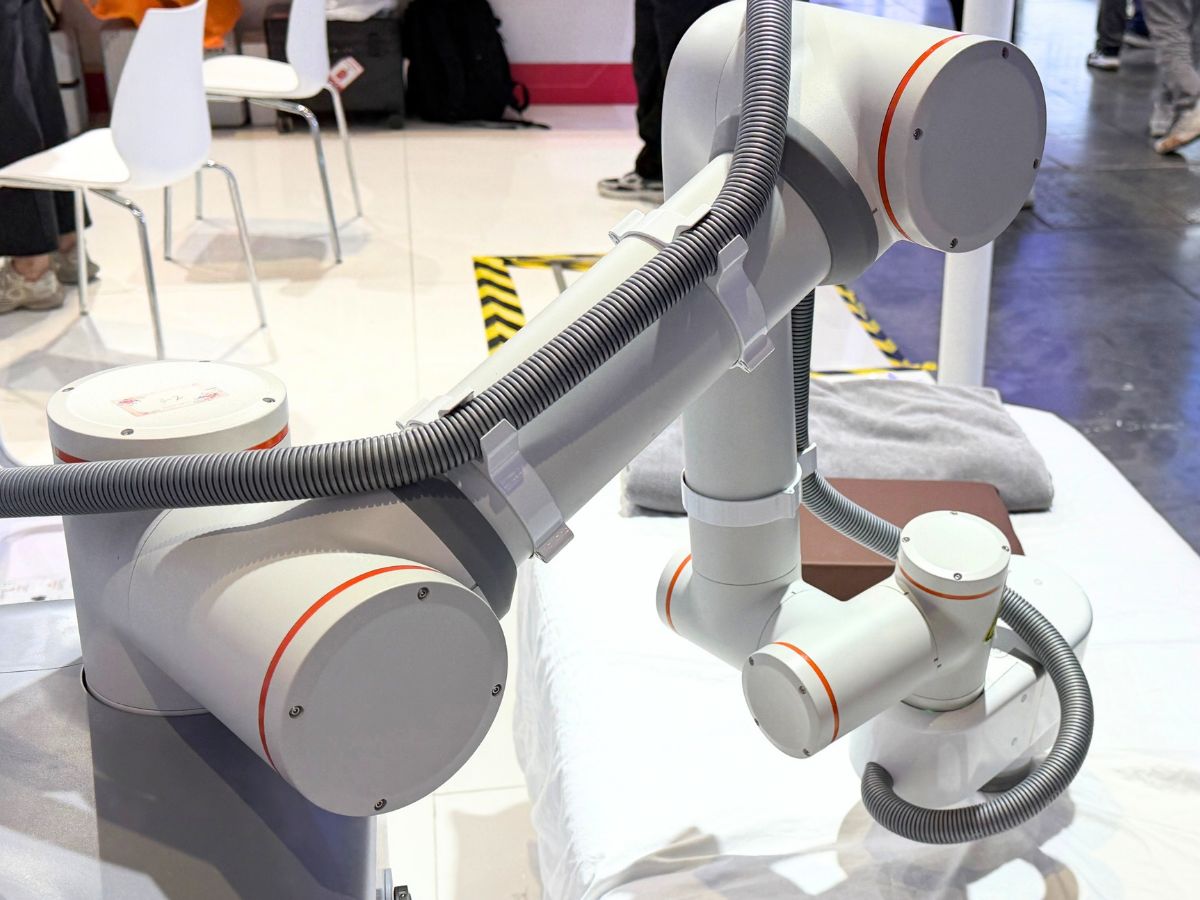
 Why Bedside Physical Therapy Robots Need Force-Controlled Joint Modules?A therapy robot does not sell a robot arm; it sells a force applied to a human body. Pressure, rhythm and depth are the prescription, and position control cannot deliver them: soft tissue is compliant and time-varying, so one position command yields contact forces that differ several-fold between muscle and bone. Force-controlled harmonic joint modules turn contact force into a closed-loop variable - the only way to make dose repeatable, human contact safe and a therapist's technique teachable. Starting from one site photo of a bedside therapy robot, this article reads the configuration, sets out five reasons force control is unavoidable, settles HONPINE's TCHL-versus-HAG choice criterion by criterion, and gives the torque sensor resolution budget that picks the frame sizes.
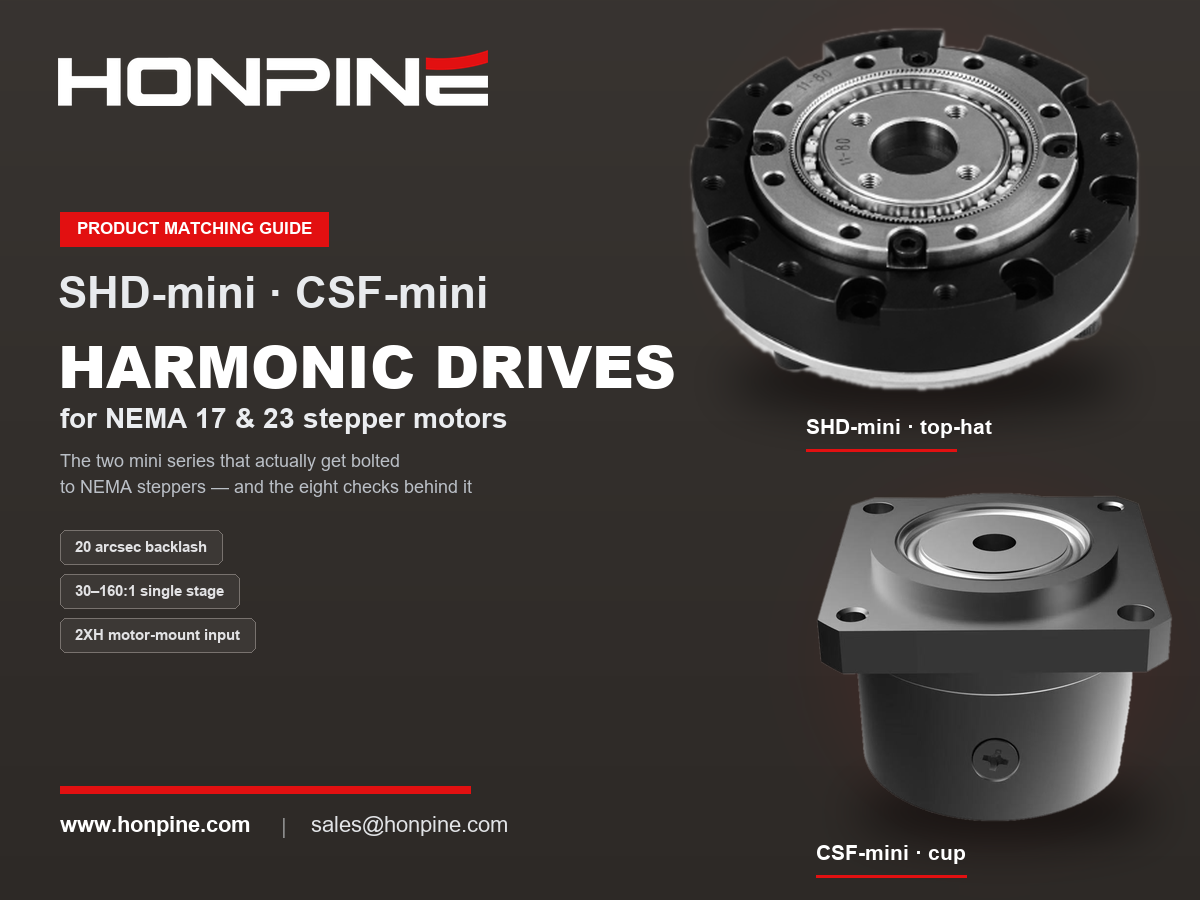
- NEMA 17 & NEMA 23 Harmonic Drive Matching Guide: Pairing Stepper Motors with Harmonic ReducersPairing a stepper motor with a harmonic drive is not a budget compromise. A stepper's weak points — the coarse step angle, torque collapse above roughly 400 rpm, and the lack of a precision transmission — are exactly what a harmonic drive fixes: it pulls the operating point into the low-speed, high-torque sweet spot, refines a 1.8° step angle into arc-second resolution, and delivers near-zero backlash. This guide explains what NEMA frame sizes mean at the mounting interface, which harmonic frames match NEMA 17 and NEMA 23, the eight checks to run in order — including the input-side no-load starting torque most often missed — and the pairing's real weakness: silent failure. Includes HONPINE SHD and CSF specifications.


{item.title}
{item.description}




