










Current tag:precision
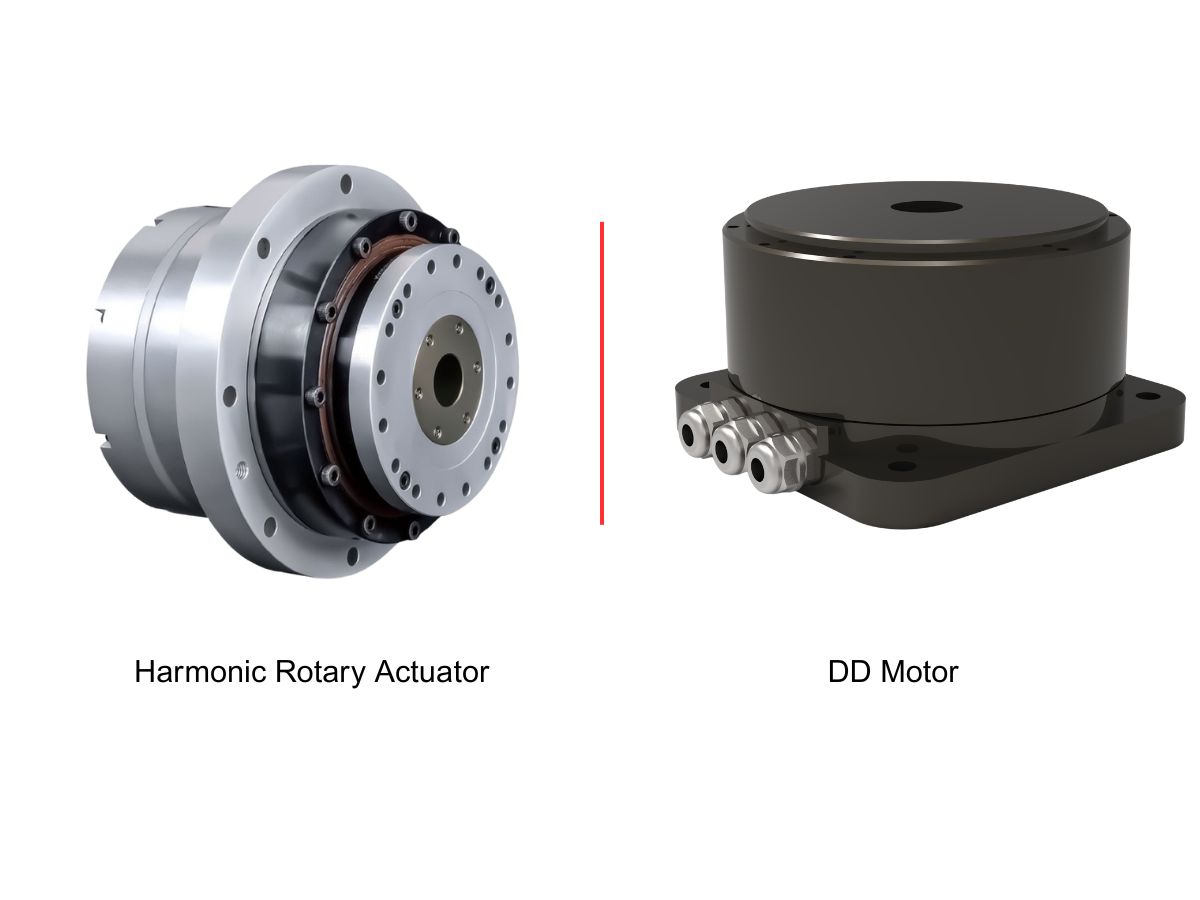
 DD Motors VS Harmonic Rotary ActuatorsThis article provides an in-depth comparison between Direct Drive (DD) motors and harmonic rotary actuators, covering their transmission principles, advantages and disadvantages, and typical application fields.
 How Do Planetary Gearboxes Reduce Speed and Increase Torque in High-Precision Automation Equipment?How does a planetary gearbox reduce speed while increasing torque in high-precision automation equipment? By combining a sun gear, multiple planet gears, and an internal ring gear, a planetary gearbox delivers compact, efficient power transmission for applications that require controlled motion and reliable torque output. From industrial robots and CNC machinery to automated assembly systems, selecting the right gearbox involves more than choosing a reduction ratio. This guide explains how planetary gearboxes work, their key advantages, common applications, and practical selection considerations to help engineers identify a suitable transmission solution.
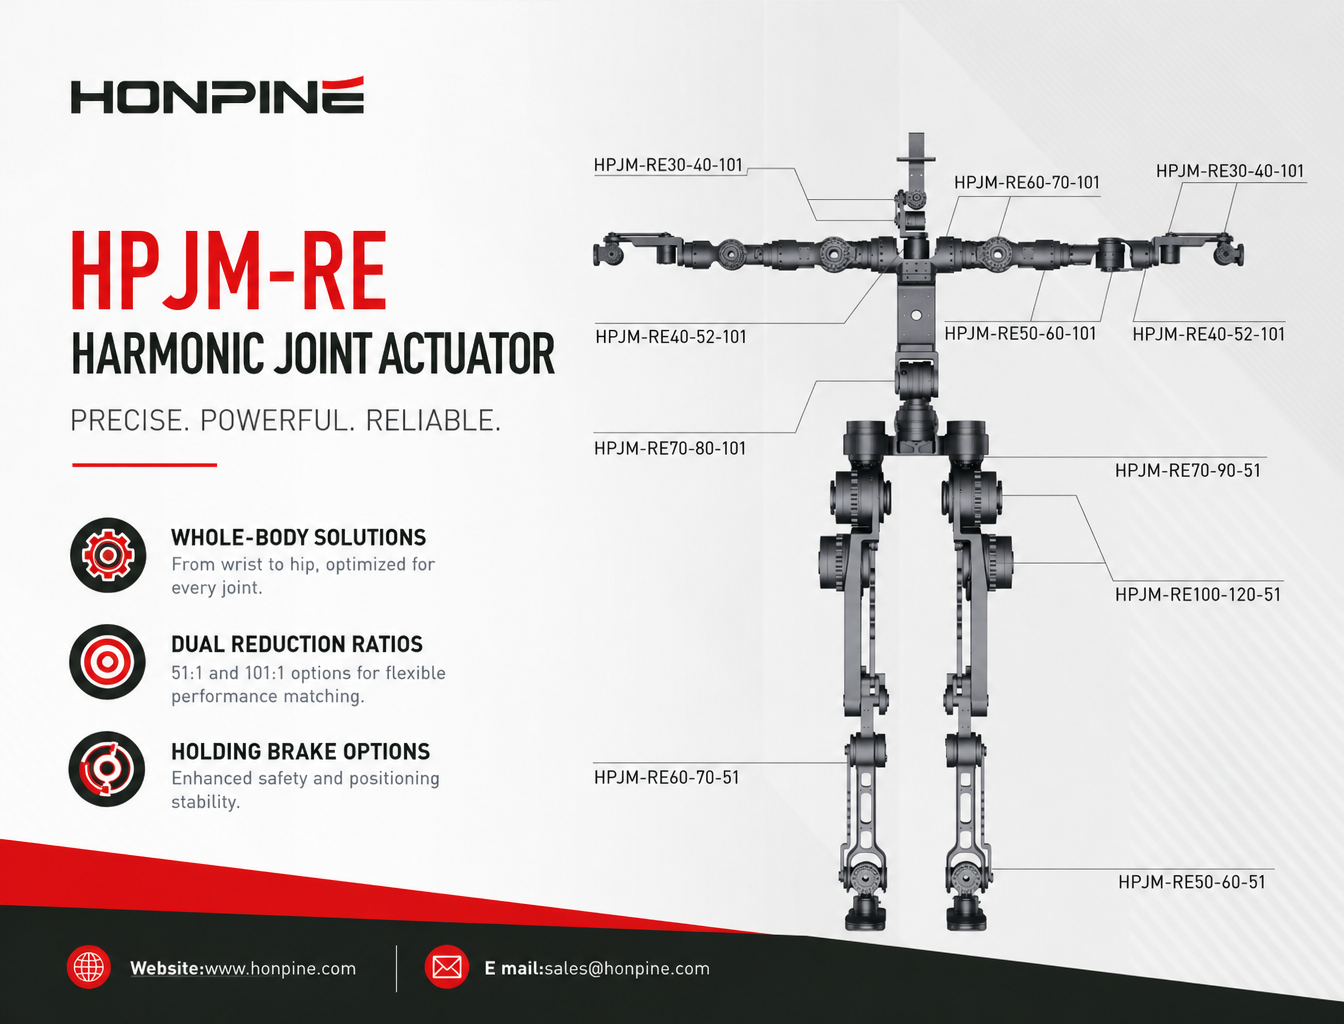
- The Complete Harmonic Joint Actuator Solution for Humanoid Robots: HPJM Series Selection GuideA complete guide to selecting harmonic joint actuators for humanoid robots. Explore HONPINE HPJM models for wrist, elbow, shoulder, waist, hip, knee, and ankle joints, with practical considerations for torque capacity, reduction ratios, dynamic response, and holding brake configurations.
- STO vs. Holding Brake in Robot Joint Modules: What Is the Difference for Robot Safe Control?STO (Safe Torque Off) and holding brakes play different roles in robot joint safety. While STO prevents a motor from generating driving torque, a holding brake mechanically resists joint movement and helps retain loads when the motor is disabled. Understanding the difference is essential when selecting a robot joint module for humanoid robots, collaborative robots, and industrial automation. In this article, Theodore Li, Technical Director at HONPINE, explains how these functions work, their limitations, and when both should be considered in a harmonic integrated joint actuator such as the HONPINE HAG series.


{item.title}
{item.description}




