










Current tag:end effector
 Should You Choose a T-Type or Straight-Type Harmonic Joint Module for a Collaborative Robot?Choosing the right harmonic joint module is essential when designing a compact, high-performance collaborative robot. Should you use a TCHL straight-type or an HTS T-type harmonic joint module? Although both configurations can support precise robotic motion, their different output flange geometries affect installation space, link connections, cable routing, and mechanical integration. In this guide, Theodore Li, Technical Director at HONPINE, explains the key differences between the two designs, their advantages and limitations, and how to select the most suitable configuration for your collaborative robotic arm.
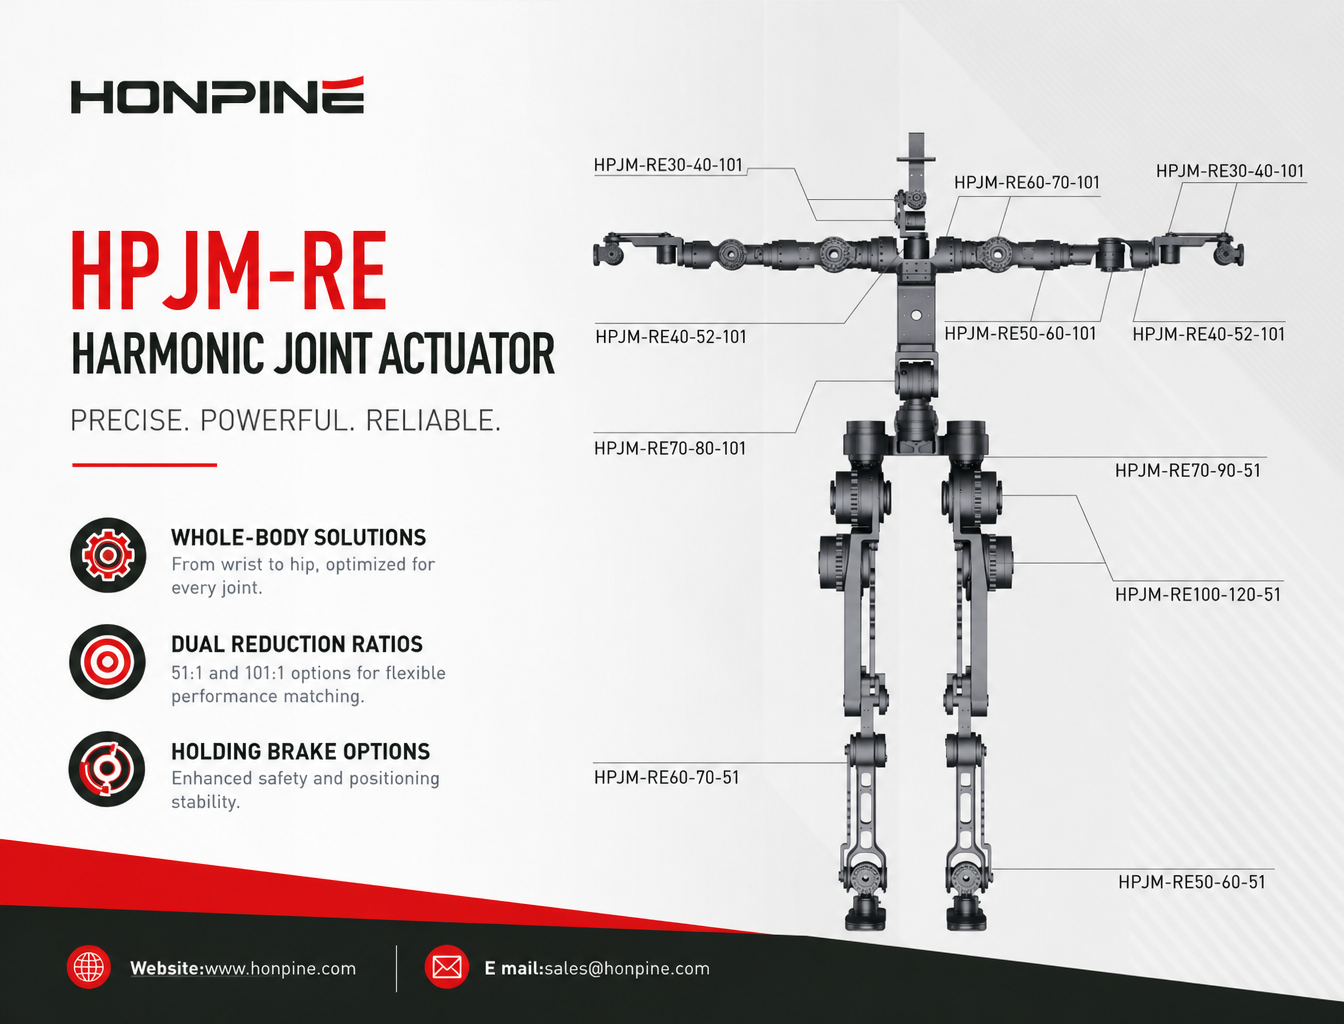
 The Complete Harmonic Joint Actuator Solution for Humanoid Robots: HPJM Series Selection GuideA complete guide to selecting harmonic joint actuators for humanoid robots. Explore HONPINE HPJM models for wrist, elbow, shoulder, waist, hip, knee, and ankle joints, with practical considerations for torque capacity, reduction ratios, dynamic response, and holding brake configurations.
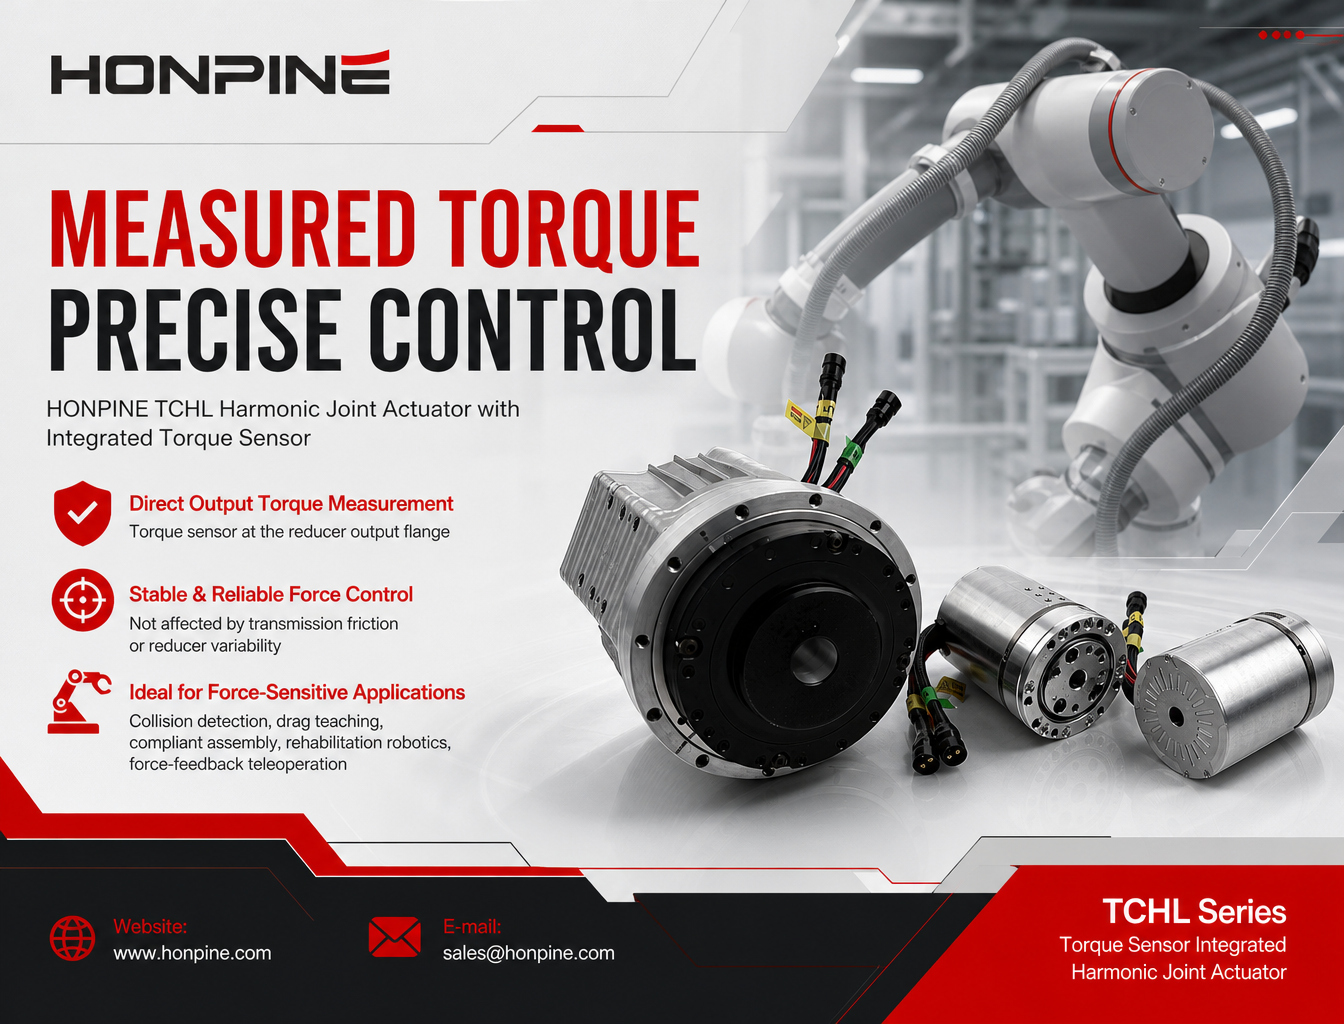
- How Does a Harmonic Joint Actuator with a Torque Sensor Improve Robot Force Control?Learn how the HONPINE TCHL harmonic joint actuator uses an integrated output torque sensor to support force feedback, collision detection, compliant assembly, rehabilitation robotics, and teleoperation.
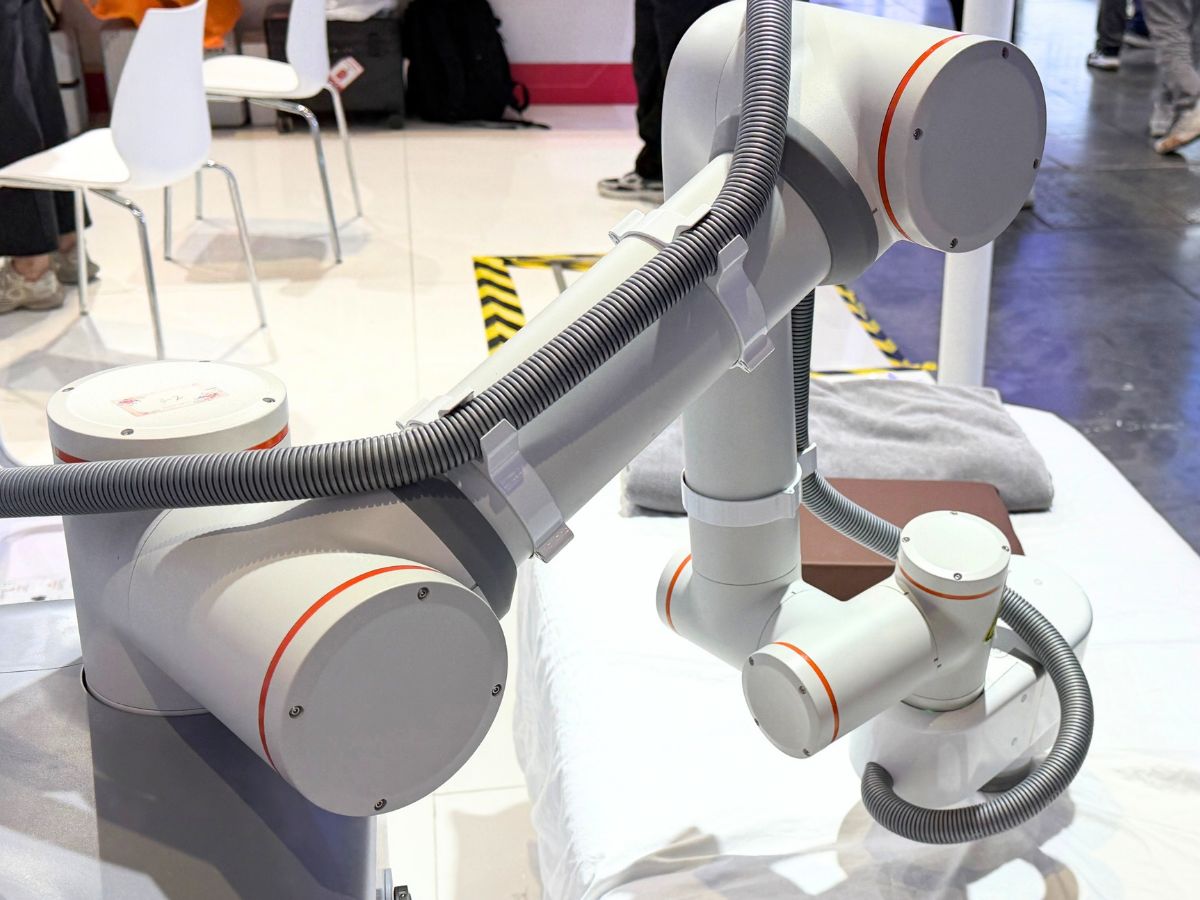
- Why Bedside Physical Therapy Robots Need Force-Controlled Joint Modules?A therapy robot does not sell a robot arm; it sells a force applied to a human body. Pressure, rhythm and depth are the prescription, and position control cannot deliver them: soft tissue is compliant and time-varying, so one position command yields contact forces that differ several-fold between muscle and bone. Force-controlled harmonic joint modules turn contact force into a closed-loop variable - the only way to make dose repeatable, human contact safe and a therapist's technique teachable. Starting from one site photo of a bedside therapy robot, this article reads the configuration, sets out five reasons force control is unavoidable, settles HONPINE's TCHL-versus-HAG choice criterion by criterion, and gives the torque sensor resolution budget that picks the frame sizes.


{item.title}
{item.description}




